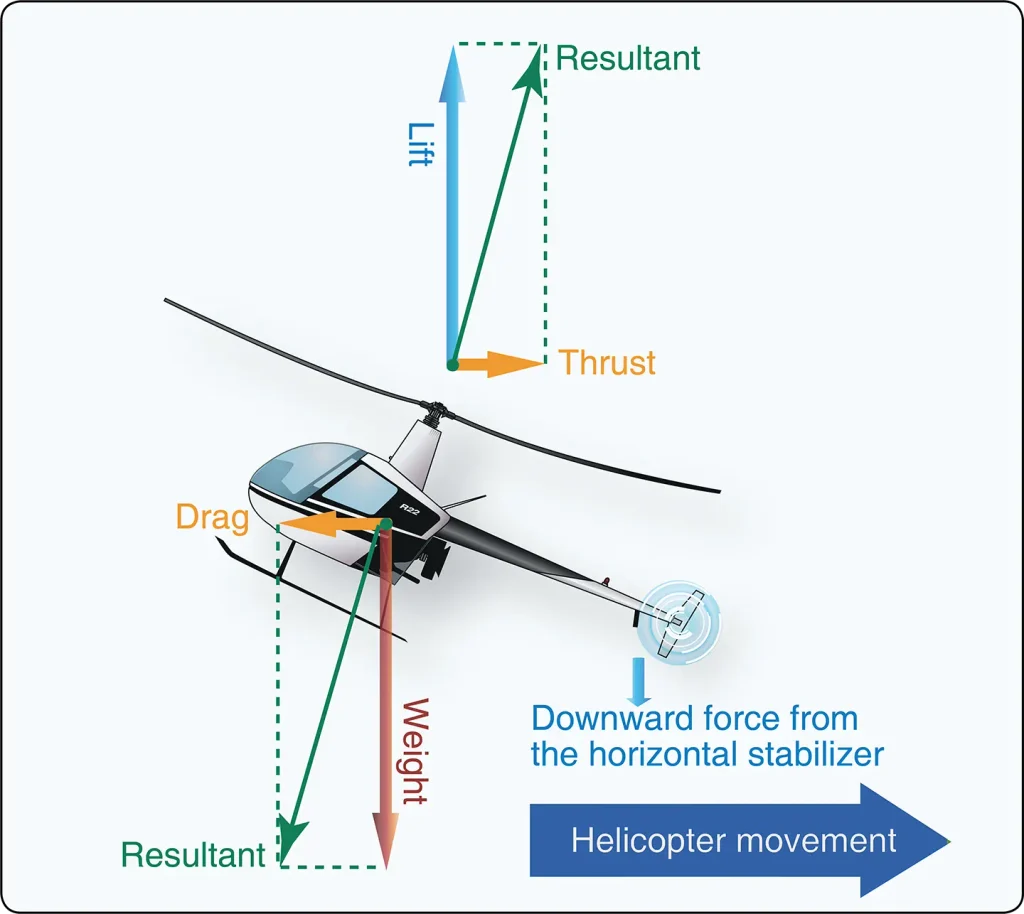
In sideward flight, the tip-path plane is tilted in the direction that flight is desired. This tilts the total lift-thrust vector sideward. In this case, the vertical or lift component is still straight up and weight straight down, but the horizontal or thrust component now acts sideward with drag acting to the opposite side. [Figure 1]
Figure 1. Forces acting on the helicopter during sideward flight
Sideward flight can be a very unstable condition due to the parasitic drag of the fuselage combined with the lack of horizontal stabilizer for that direction of flight. Increased altitudes help with control and the pilot must always scan in the direction of flight.
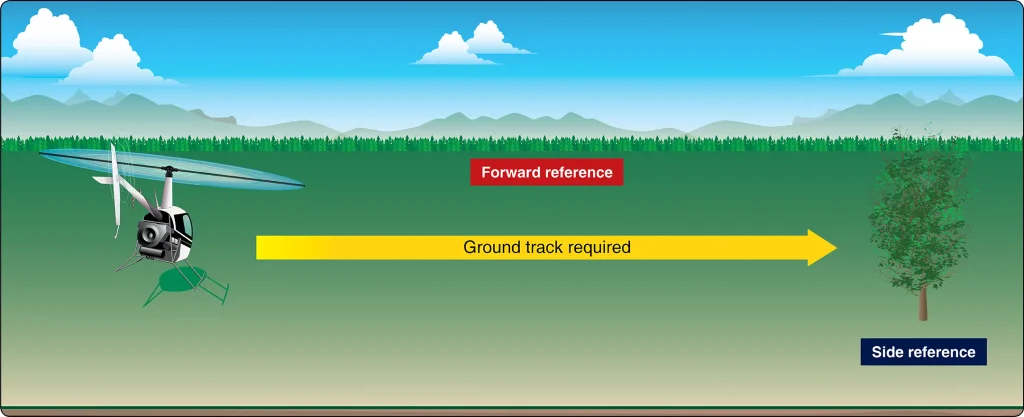
Movement of the cyclic in the intended direction of flight causes the helicopter to move, controls the rate of speed, and ground track, but the collective and pedals are key to successful sideward flight. Just as in forward flight, the collective keeps the helicopter from contacting the ground and the pedals help maintain the correct heading; even in sideward flight, the tail of the helicopter should remain behind you. Inputs to the cyclic should be smooth and controlled, and the pilot should always be aware of the tip-path plane in relation to the ground. [Figure 2]
Figure 2. Forces acting on the helicopter during sideward flight
Contacting the ground with the skids during sideward flight will most likely result in a dynamic rollover event before the pilot has a chance to react. Extreme caution should be used when maneuvering the helicopter sideways to avoid such hazards from happening.
Rearward Flight
For rearward flight, the tip-path plane is tilted rearward, which, in turn, tilts the lift-thrust vector rearward. Drag now acts forward with the lift component straight up and weight straight down. [Figure 3]
Figure 3. Forces acting on the helicopter during rearward flight
Pilots must be aware of the hazards of rearward flight. Because of the position of the horizontal stabilizer, the tail end of the helicopter tends to pitch downward in rearward flight, causing the probability of hitting the ground to be greater than in forward flight. Another factor to consider in rearward flight is skid design. Most helicopter skids are not turned upward in the back, and any contact with the ground during rearward flight can put the helicopter in an uncontrollable position leading to tail rotor contact with the ground. Pilots must do a thorough scan of the area before attempting to hover rearward, looking for obstacles and terrain changes. Slower airspeeds can help mitigate risk and maintain a higher-than-normal hover altitude.
Turning Flight
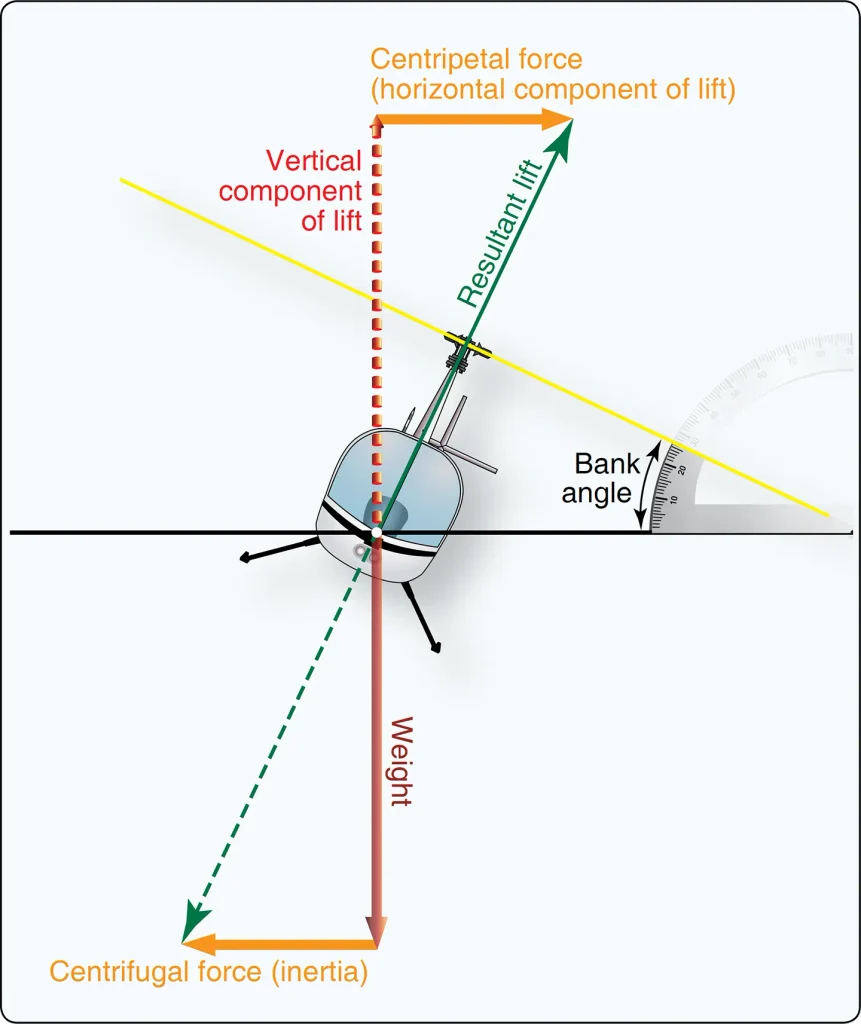
In forward flight, the rotor disk is tilted forward, which also tilts the total lift-thrust force of the rotor disk forward. When the helicopter is banked, the rotor disk is tilted sideward resulting in lift being separated into two components. Lift acting upward and opposing weight is called the vertical component of lift. Lift acting horizontally and opposing inertia (centrifugal force) is the horizontal component of lift (centripetal force). [Figure 4]
Figure 4. Forces acting on the helicopter during turning flight
As the angle of bank increases, the total lift force is tilted more toward the horizontal, thus causing the rate of turn to increase because more lift is acting horizontally. Since the resultant lifting force acts more horizontally, the effect of lift acting vertically is decreased. To compensate for this decreased vertical lift, the AOA of the rotor blades must be increased in order to maintain altitude. The steeper the angle of bank is, the greater the AOA of the rotor blades required to maintain altitude. Thus, with an increase in bank and a greater AOA, the resultant lifting force increases and the rate of turn is higher. Simply put, collective pitch must be increased in order to maintain altitude and airspeed while turning. Collective pitch controls the angle of incidence and along with other factors, determines the overall AOA in the rotor disk.
We use cookies to ensure our website functions properly, analyze website traffic, and improve your browsing experience. You can accept all cookies, reject non-essential cookies, or customize your preferences.
Used to monitor number of Google Analytics server requests
10 minutes
__utmb
Used to distinguish new sessions and visits. This cookie is set when the GA.js javascript library is loaded and there is no existing __utmb cookie. The cookie is updated every time data is sent to the Google Analytics server.
30 minutes after last activity
__utmc
Used only with old Urchin versions of Google Analytics and not with GA.js. Was used to distinguish between new sessions and visits at the end of a session.
End of session (browser)
__utmz
Contains information about the traffic source or campaign that directed user to the website. The cookie is set when the GA.js javascript is loaded and updated when data is sent to the Google Anaytics server
6 months after last activity
__utmv
Contains custom information set by the web developer via the _setCustomVar method in Google Analytics. This cookie is updated every time new data is sent to the Google Analytics server.
2 years after last activity
__utmx
Used to determine whether a user is included in an A / B or Multivariate test.
18 months
_ga
ID used to identify users
2 years
_gali
Used by Google Analytics to determine which links on a page are being clicked
30 seconds
_ga_
ID used to identify users
2 years
_gid
ID used to identify users for 24 hours after last activity
24 hours
_gat
Used to monitor number of Google Analytics server requests when using Google Tag Manager
1 minute
_gac_
Contains information related to marketing campaigns of the user. These are shared with Google AdWords / Google Ads when the Google Ads and Google Analytics accounts are linked together.